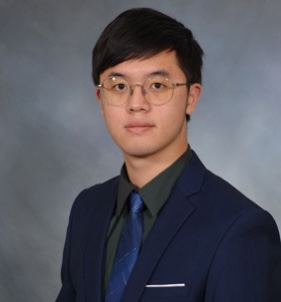
Hi! I'm a Ph.D. candidate in Mechanical Engineering at Yale University, advised by Prof. Ian Abraham.
I develop robot learning systems that combine sampling-based control, visual policies, and coding agents for locomotion and dexterous manipulation. My work spans vision-language-action models, simulation-to-real transfer, and autonomous exploration.
I'm on the job market for full-time positions and expect to graduate in 2027. Please see my CV. If you think I'd be a good fit for your team, please reach out!
News
- Introducing EmbodiedSWE: coding agents for long-horizon dexterous robotics.
- Our Sampling-Guided Policy Search paper is available on arXiv.
- SDPG accepted to CoRL 2026.
- Our ergodic coverage paper accepted to RSS 2026.
- Sample-Based Hybrid Mode Control accepted to ICRA 2026.
- D.Va accepted to NeurIPS 2025 as a Spotlight.
Selected Publications
Experience
-
Robotics Intern · Santa Clara, CA
Education
-
Yale University
Expected
Ph.D. in Mechanical Engineering · Candidate
-

Carnegie Mellon University
M.S. in Mechanical Engineering · Research Program
-
University of Cincinnati & Chongqing University
Dual-degree program
B.S. in Mechanical Engineering, cum laude — University of Cincinnati
B.E. in Mechanical Design, Manufacture and Automation — Chongqing University
Service
IEEE Robotics and Automation Letters (RA-L); ICRA 2022–2026; IROS 2022–2026; ECCV 2024; RSS 2025.